
Abstract
Imitation learning-based robot control policies are enjoying renewed interest in video-based robotics. However, it remains unclear whether this approach applies to X-ray-guided procedures, such as spine instrumentation, with sparse inputs. We examine the feasibility, opportunities and challenges for imitation policy learning in bi-plane-guided cannula insertion.
We develop an in silico sandbox for scalable, automated simulation of X-ray-guided spine procedures with a high degree of realism. We curate a dataset of correct trajectories and corresponding bi-planar X-ray sequences that emulate the stepwise alignment of providers. We then train imitation learning policies for planning and open-loop control that iteratively align a cannula in a vertebroplasty setting solely based on visual information. This precisely controlled setup offers insights into limitations and capabilities of this method.
Our policy succeeded on the first attempt in 68.5% of cases, maintaining safe intra-pedicular trajectories across diverse vertebral levels. The policy transferred to complex anatomy, including fractures, as well as varied anatomies and initializations. Rollouts on real X-ray indicate that partial sim-to-real transfer with plausible trajectories is possible.
While these preliminary results are promising, we also identify limitations, especially in entry point precision. The current results present a clear benchmark for future efforts, while with more robust priors and domain knowledge, such models may provide a foundation for future efforts toward lightweight and CT-free robotic intra-operative spinal navigation.
Figures
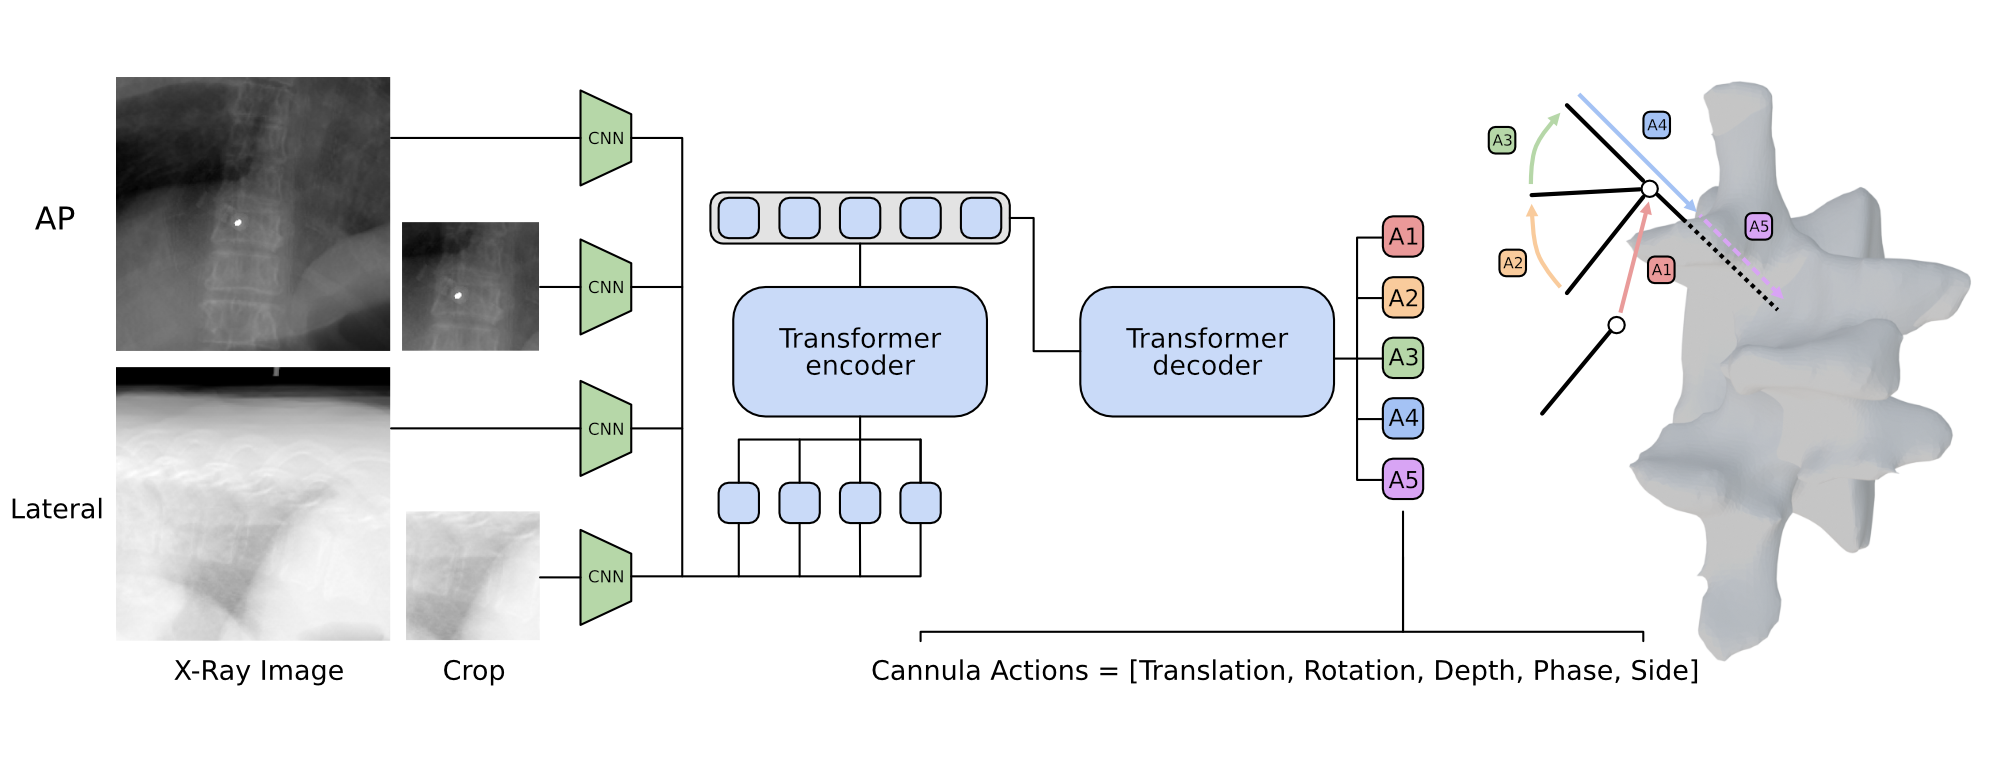
Overview. Left to right: Inputs consisting of current AP and lateral observations are processed via a conditional variational autoencoder. Fine-grain pose adjustments for cannula are predicted as actions to generate final insertion trajectory while modeling surgeon like adjustments.
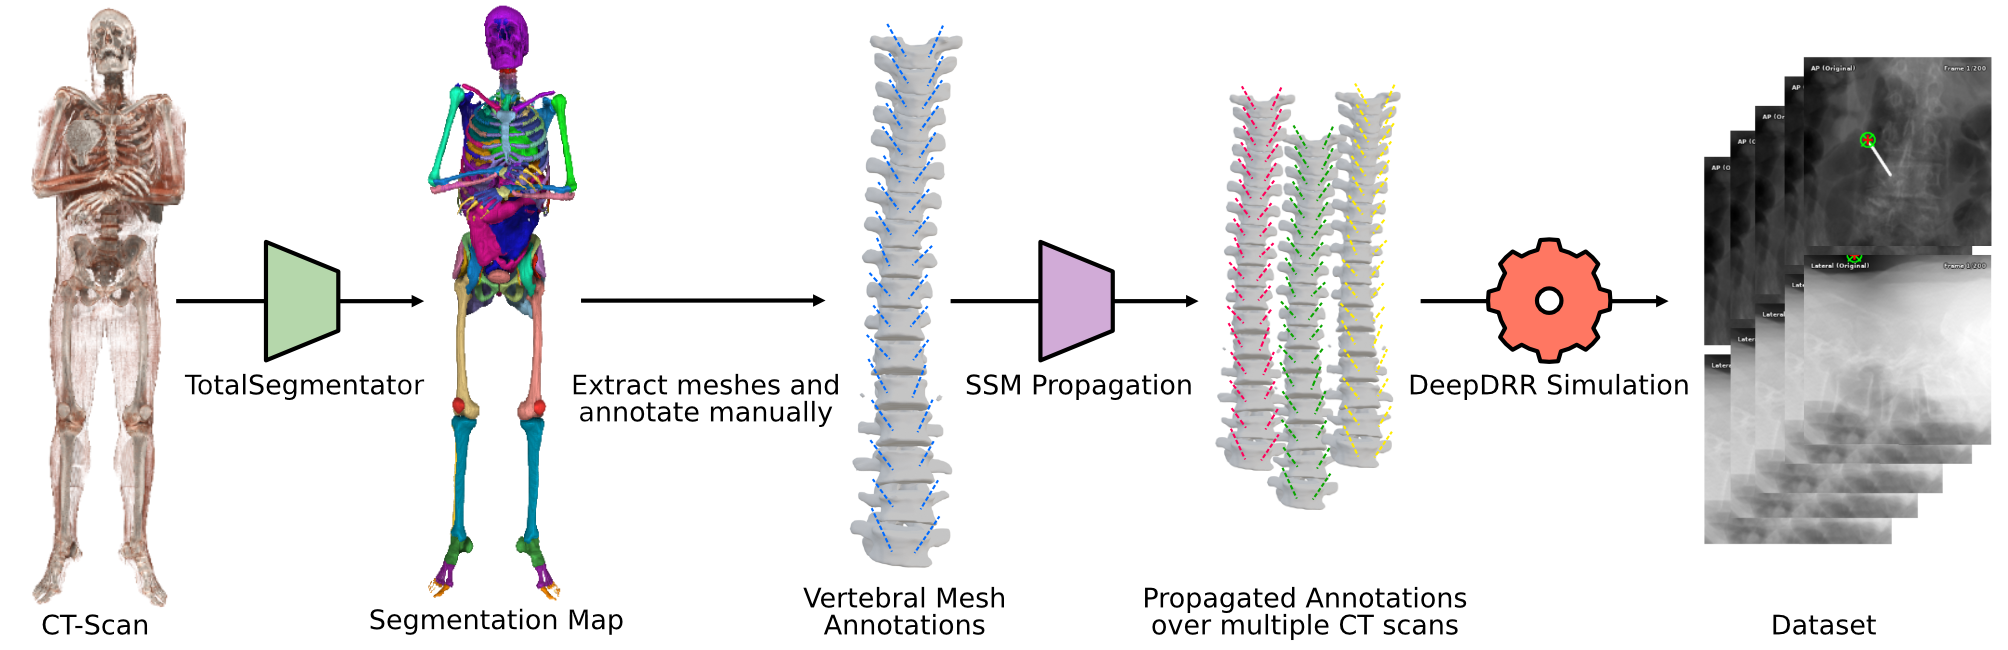
Dataset Generation Pipeline. Left to right: CT-scans from the NMDID dataset are preprocessed using TotalSegmentator. Then representative Statistical Shape Models are extracted, manually annotated and propagated over multiple CT scans. Lastly annotations are simulated via DeepDRR to generate our training data.
Method
To enable surgeon-like spinal trajectory planning directly from bi-planar X-rays we train a transformer-based imitation learning policy using an incremental action representation that predicts cannula adjustments from AP and lateral radiographs. A high-level overview of the model and our approach can be found above. The large-scale annotated training data required to train such a model is generated by constructing a realistic simulation environment with automatically derived safe trajectories. The data generation pipeline consists of three main components: (1) preprocessing of clinical CT data and segmentation, (2) generation and filtering of safe trajectories, (3) simulation of bi-planar radiographs, with the full pipeline being illustrated in the figures above.
Citation
Klitzner, F., Inigo Romillo, B., Killeen, B. D., Seenivasan, L., Song, M., Choi, R., Khan, M., Krieger, A., & Unberath, M. (2026).
Investigating robot control policy learning for autonomous x-ray-guided spine procedures.
International Journal of Computer Assisted Radiology and Surgery, 21(6), 1387–1396.
https://doi.org/10.1007/s11548-026-03716-x
@article{Klitzner_2026,

                      title={Investigating robot control policy learning for autonomous x-ray-guided spine procedures},

                      author={Klitzner, Florence and Inigo Romillo, Blanca and Killeen, Benjamin D. and Seenivasan, Lalithkumar and Song, Michelle and Choi, Rebecca and Khan, Majid and Krieger, Axel and Unberath, Mathias},

                      journal={International Journal of Computer Assisted Radiology and Surgery},

                      volume={21},

                      number={6},

                      pages={1387--1396},

                      year={2026},

                      publisher={Springer},

                      doi={10.1007/s11548-026-03716-x}

                    }